01Human input
Live Teleoperation
Capture demonstrations
Operators use sensor-equipped gloves to record the dexterous decisions and movements real tasks require.
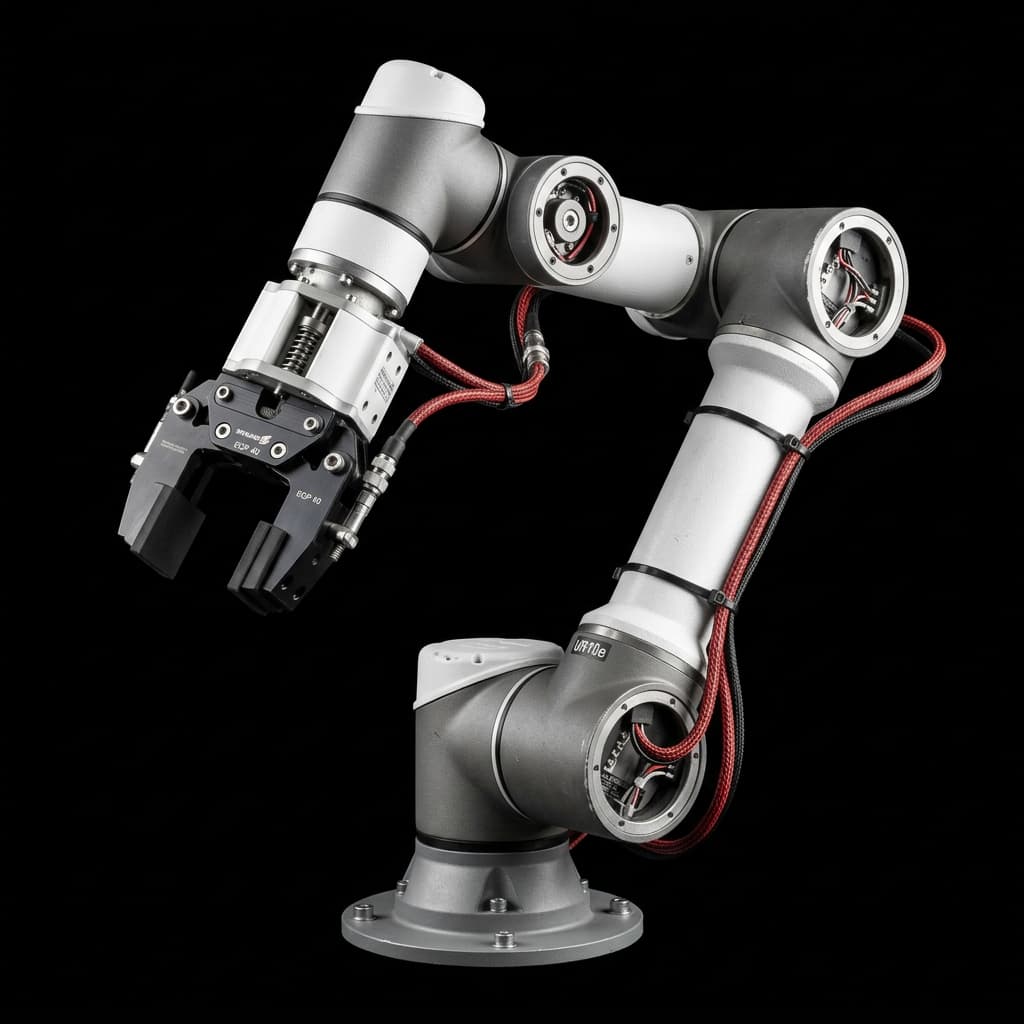
We build foundation models for robotic manipulation - deploying bots with human-level dexterity and reasoning in the real world.
Operators use sensor-equipped gloves to record the dexterous decisions and movements real tasks require.
Multi-modal models turn human demonstrations into policies that can reason about contact, motion and intent.
Robots execute in real environments, revealing edge cases that become the next generation of training data.
Continuous Loop: Real-world edge cases stream back to training data.
Built by talent from


